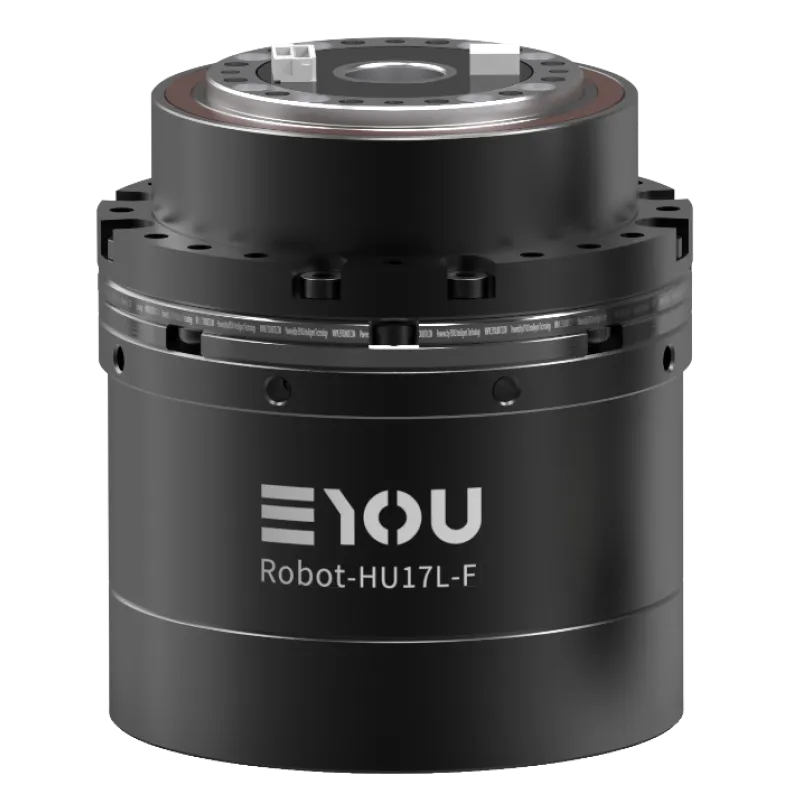
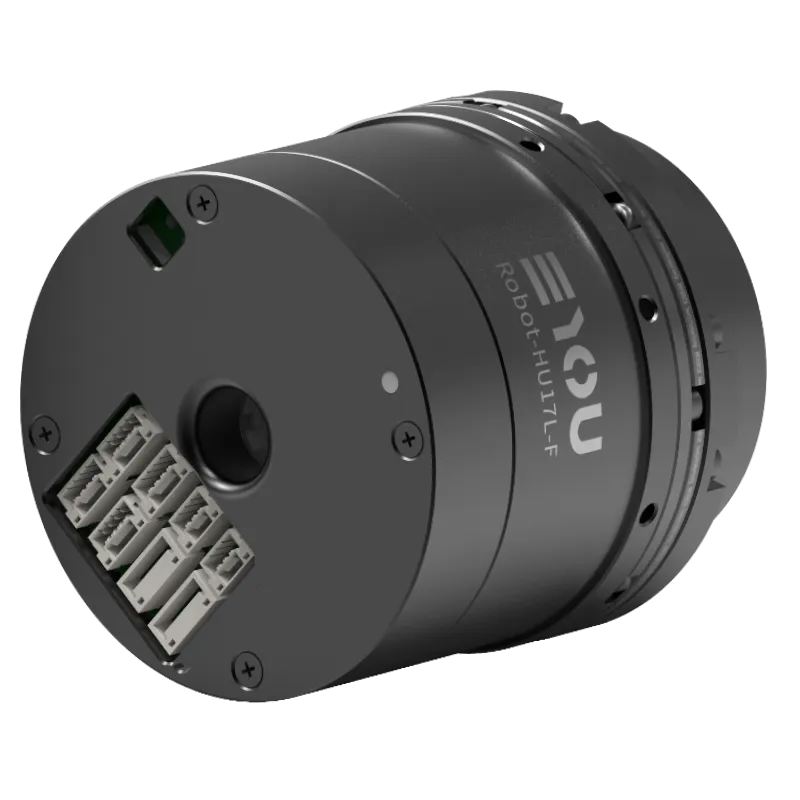
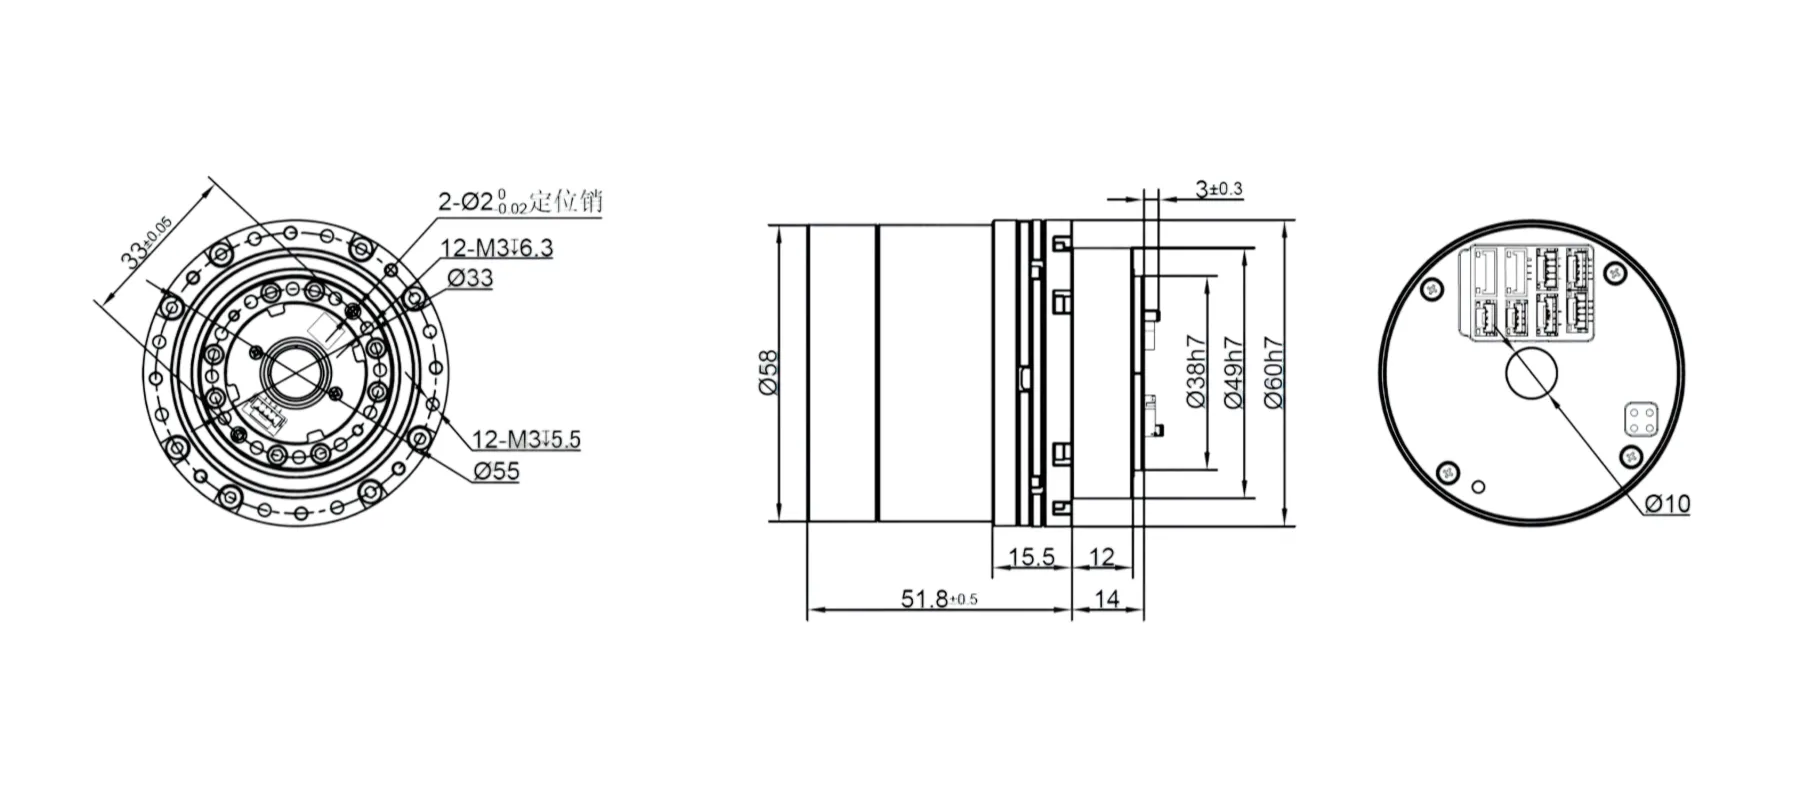
Force-control humanoid harmonic joint module with a 60 mm outer diameter, 10 mm hollow bore, 24–48 V operation, dual absolute encoders and EtherCAT/CANopen communication. The official page lists multiple reduction-ratio and torque configurations.
Specifications
| Outer diameter | 60 mm |
|---|---|
| Dimensions / length | 66 mm |
| Hollow bore diameter | 10 mm |
| Weight | 0.521 kg (N configuration; B configuration 0.538 kg) |
| Reduction ratio | 50 / 80 / 100 |
| Operating voltage | 24–48 V |
| Rated output power | 46 / 39 / 34 W |
| Rated torque at 2,000 rpm | 11 / 15 / 16 N·m |
| Peak start-stop output torque | 23 / 29 / 37 N·m |
| Encoder type | absolute (dual absolute encoders) |
| Communication protocol | EtherCAT|CANopen |
| Technical extension | Average output torque: 18 / 19 / 27 N·m; maximum allowable momentary torque: 48 / 61 / 71 N·m; torque accuracy ≤±0.5% FS; sensor resolution 0.1% FS; sampling frequency ≥5 kHz; encoder accuracy 19 bit; power-off brake optional. Ratios in the source table correspond positionally to each listed torque/power series. |